I am currently a Research Scientist Intern at Meta Reality Labs, where I work on building large-scale data generation and evaluation environments for robotics.
I recently defended my PhD in Machine Learning at the University of Cambridge, under the supervision of Professor Joan Lasenby, where I also worked with Elliott Wu towards the end. My research focuses on two main directions: coding agents for simulation (LiteReality, LiteReality-Agent, Articraft) and video world models (SpaceTimePilot). More recently, my work has increasingly shifted towards developing interactive, large-scale simulation environments for robotics.
I am actively looking for full-time positions starting January 2027 in robotics, simulation, and video world models. Whether you are hiring or just want to talk research in these areas, feel free to reach out.
Based in King’s Cross, London
News
[Nov 2026] Started Research Scientist Intern at Meta Reality Labs, the final stop of the PhD journey!
[May 2026]Articraft is out everywhere! The technical report, the code, and the Articraft-10K dataset are all available. Articraft is an agentic system that writes programs to generate articulated 3D assets at scale.
More news
[April 2026] Started an internship at Morpheus AI, working on video world models with Xun Huang and Yicong Hong.
[Feb 2026] SpaceTimePilot is accepted at CVPR 2026! Huge thanks to all the co-authors! We are working on releasing the codebase and dataset.
[Jan 2026] We released the codebase for LiteReality! You can use it to scan your room and convert it to a compact, graphics-ready reconstruction with full PBR materials. Check out the code and examples.
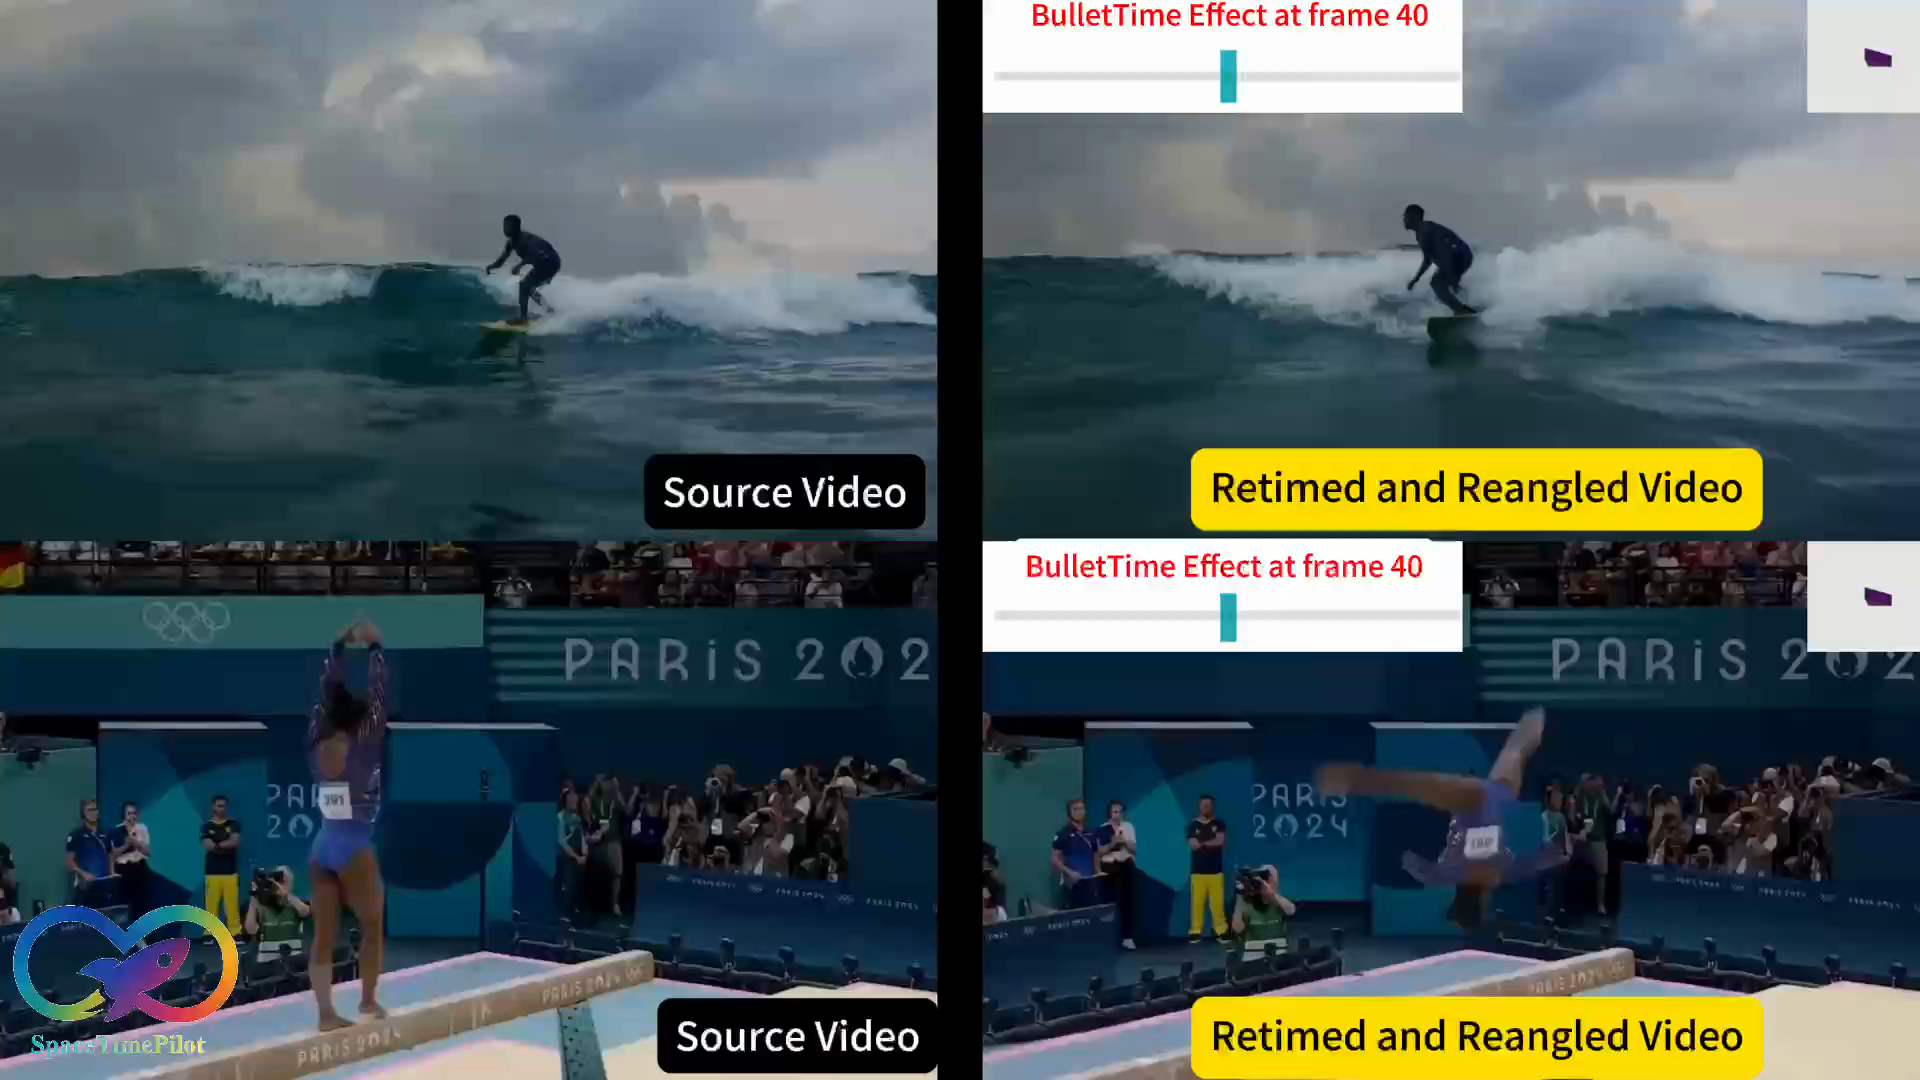
[Dec 2025] We released SpaceTimePilot. Check out the video and webpage. SpaceTimePilot disentangles space and time in video diffusion model, for implicit 4D reconstruction and exploration.
[Oct 2025] Fortunate to receive the NeurIPS 2025 Scholar Award! Grateful for the support.
[Sep 2025] LiteReality is accepted at NeurIPS 2025! Thanks to all the collaborators.
TLDR: LiteReality-Agent is an open-source, end-to-end toolkit for reconstructing simulation-ready rooms. Scan a room with the iOS LiDAR app, and the agent authors the room as a Python program, producing a simulation-ready room with articulated assets in a simulation engine.
TLDR: Articraft reduces articulated 3D asset generation to writing a program that builds the asset, and uses an LLM agent with a domain-specific SDK and validation harness to write those programs automatically.
TLDR: SpaceTimePilot disentangles space and time in a video diffusion model for controllable generative rendering. Given a single input video of a dynamic scene, it steers both the camera viewpoint and the temporal motion within the scene, enabling free exploration across the 4D space–time domain.
TLDR: LiteReality is an automatic pipeline that converts RGB-D scans of indoor environments into graphics-ready scenes with high-quality meshes, PBR materials, and articulated objects ready for rendering and physics-based interactions.
TLDR: OpenIns3D proposes a "mask-snap-lookup" scheme to achieve 2D-input-free 3D open-world scene understanding, which attains SOTA performance across datasets, even with fewer input prerequisites.
Service
Reviewer for CVPR, ICCV, ECCV, NeurIPS, ICML, ICLR, SIGGRAPH, SIGGRAPH Asia, Eurographics, and 3DV.